The team
behind.

Grounded in research, driven to build.

CEO

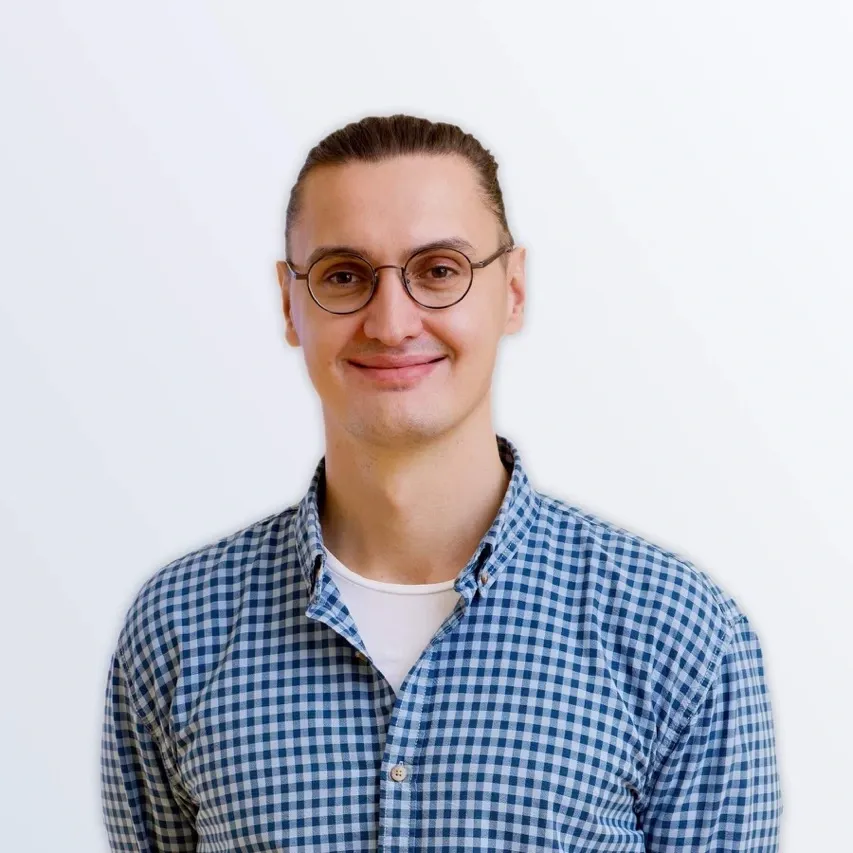
Luca Di Pierno

BSc & MSc ETH Zurich

PhD candidate in Robotics

University of Klagenfurt · CNS group

Robotics & intelligent systems

Luca studied Mechanical Engineering at ETH Zurich (BSc and MSc) before joining the Control of Networked Systems group at the University of Klagenfurt, where he is completing a PhD in Robotics under Prof. Stephan Weiss.

His research centres on autonomy for aerial and space robots: multi-agent systems, real-time perception and collaborative decision-making in GPS-denied environments. As a visiting researcher at NASA’s Jet Propulsion Laboratory he worked on autonomy frameworks for space exploration, presented at IEEE CASE 2025.

Luca led the HERMES team that won Stage 2 of SPRIN-D’s Fully Autonomous Flight 2.0 Challenge in 2026, developing its core autonomy and overall navigation architecture. He also leads the University of Klagenfurt’s SAPIENCE team, which builds cooperative search-and-rescue UAVs for GPS-denied environments and won the NATO SPS SAPIENCE competition in Huntsville, USA, in 2025.

At Vasco he leads the company and its overall technical direction.

COO

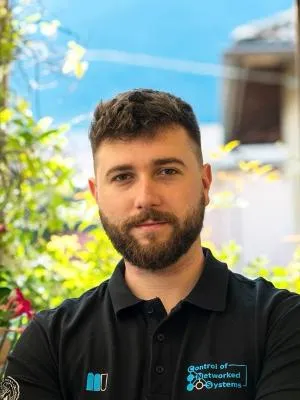
Roman Bögli

BSc FHNW & MSE OST

PhD candidate in Computer Science

University of Bern · SEG

Software engineering & security

Roman is a PhD candidate in the Software Engineering Group at the University of Bern, where he has worked since 2024. His research focuses on software variability, applied cryptography and decentralized systems.

For his master’s thesis, he worked as a student researcher in the Decentralized Trust team within IBM Research’s Security Research Department in Rüschlikon. His research addressed privacy-protecting and post-quantum secure digital asset protocols.

He brings more than a decade of experience across project management, software engineering and research, including industry roles at VZ VermögensZentrum and reByte. This experience informs his DevSecOps approach to integrating security throughout the software lifecycle. He holds an MSE in Computer Science with a focus on cybersecurity from OST and a BSc in Business Information Technology from FHNW. His studies included exchanges in Australia and Canada.

At Vasco, he oversees software architecture and lifecycle processes, contributes to secure communication, and leads company operations.

CTO

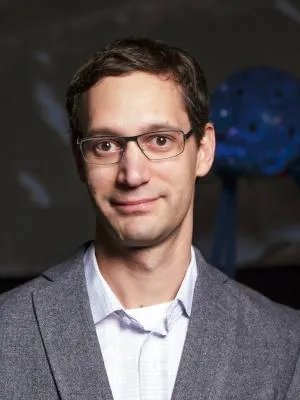
Giulio Delama

BSc & MSc Mechatronics Engineering

PhD candidate in Robotics

University of Klagenfurt · CNS group

Navigation & sensor fusion

Giulio is an engineer with a background in mechatronics and control systems. He is completing a PhD in Robotics in the Control of Networked Systems group at the University of Klagenfurt under Prof. Stephan Weiss.

His research focuses on geometric methods and equivariant systems theory for state estimation, multi-sensor fusion and inertial navigation: the mathematics that keeps an aircraft’s estimate of where it is consistent when GPS is gone. His work includes UVIO, an UWB-aided visual-inertial odometry framework, equivariant IMU preintegration on the Galilean group, and equivariant filters for radar-inertial odometry.

Beyond the papers, he builds the C++ libraries behind this work: Lie group operations, IMU preintegration and sensor-fusion frameworks that fly on real research aircraft.

At Vasco he leads the technology: navigation, state estimation and the sensor-fusion core of the autonomy brain.

Advisory board

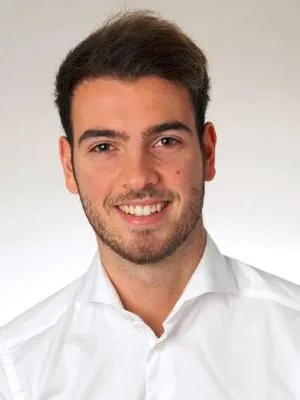
Prof. Dr. Stephan Weiss

MSc & PhD ETH Zurich

Full Professor · Chair of CNS

University of Klagenfurt

Robotics, sensor fusion, and autonomous navigation.
Stephan Weiss received his MSc in Electrical Engineering and Information Technology in 2008 and his PhD in 2012 from ETH Zurich, with the thesis “Vision Based Navigation for Micro Helicopters” at the Autonomous Systems Lab under Prof. Roland Siegwart.

From 2012 to 2015 he was a Research Technologist at NASA’s Jet Propulsion Laboratory in the Mobility and Robotic Systems Section and lectured at the California Institute of Technology. His algorithms were key to the Mars Helicopter Scout proposal and its proof-of-concept demonstration, the line of work that led to the Mars Ingenuity helicopter.

Since October 2015 he is Full Professor for Control of Networked Systems at the University of Klagenfurt. His group works on state estimation, sensor fusion, motion planning and autonomy for mobile systems in GPS-denied environments, and guided the HERMES team that won SPRIN-D’s Fully Autonomous Flight 2.0 Challenge.

Advisory board

Prof. Dr. Timo Kehrer

PhD University of Siegen

Full Professor · Chair of SEG

University of Bern

Software engineering and automation for autonomous systems.

Timo Kehrer received his PhD from the University of Siegen. He was a postdoctoral fellow at Politecnico di Milano, a visiting researcher at the University of Leicester and an assistant professor at Humboldt-Universität zu Berlin before joining the University of Bern in January 2022 as Professor and Chair of the Software Engineering Group.

His research covers software evolution and variability management, model-driven engineering and graph transformation, software product lines and configuration systems, and software engineering for scientific and computational systems.

He is President of CHOOSE, the Swiss Group for Software Engineering, a board member of Informatics Europe, General Chair of SE 2026 and VaMoS’24, and serves on the programme committees of ICSE, FSE, ASE and MODELS.

He advises Vasco on software architecture, variability and verifiable engineering practice for autonomous systems.

Where our team trained and researched, and the programmes that tested our technology.