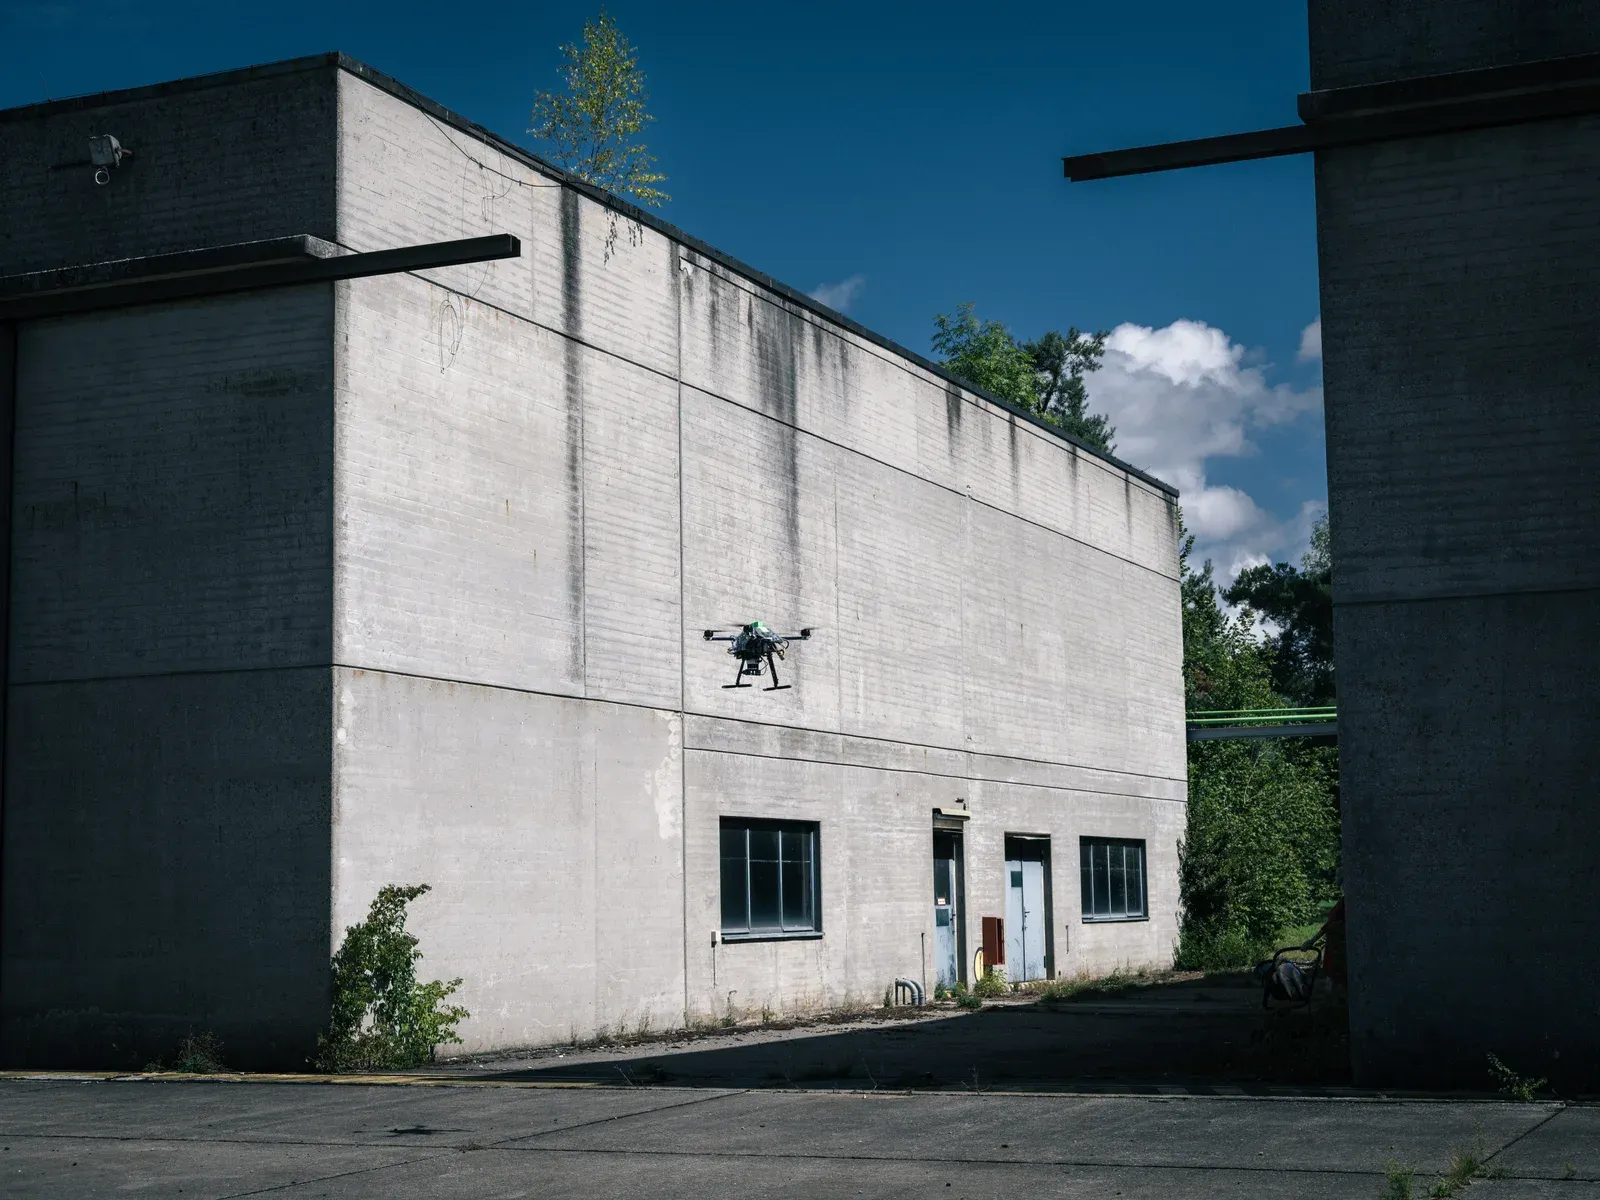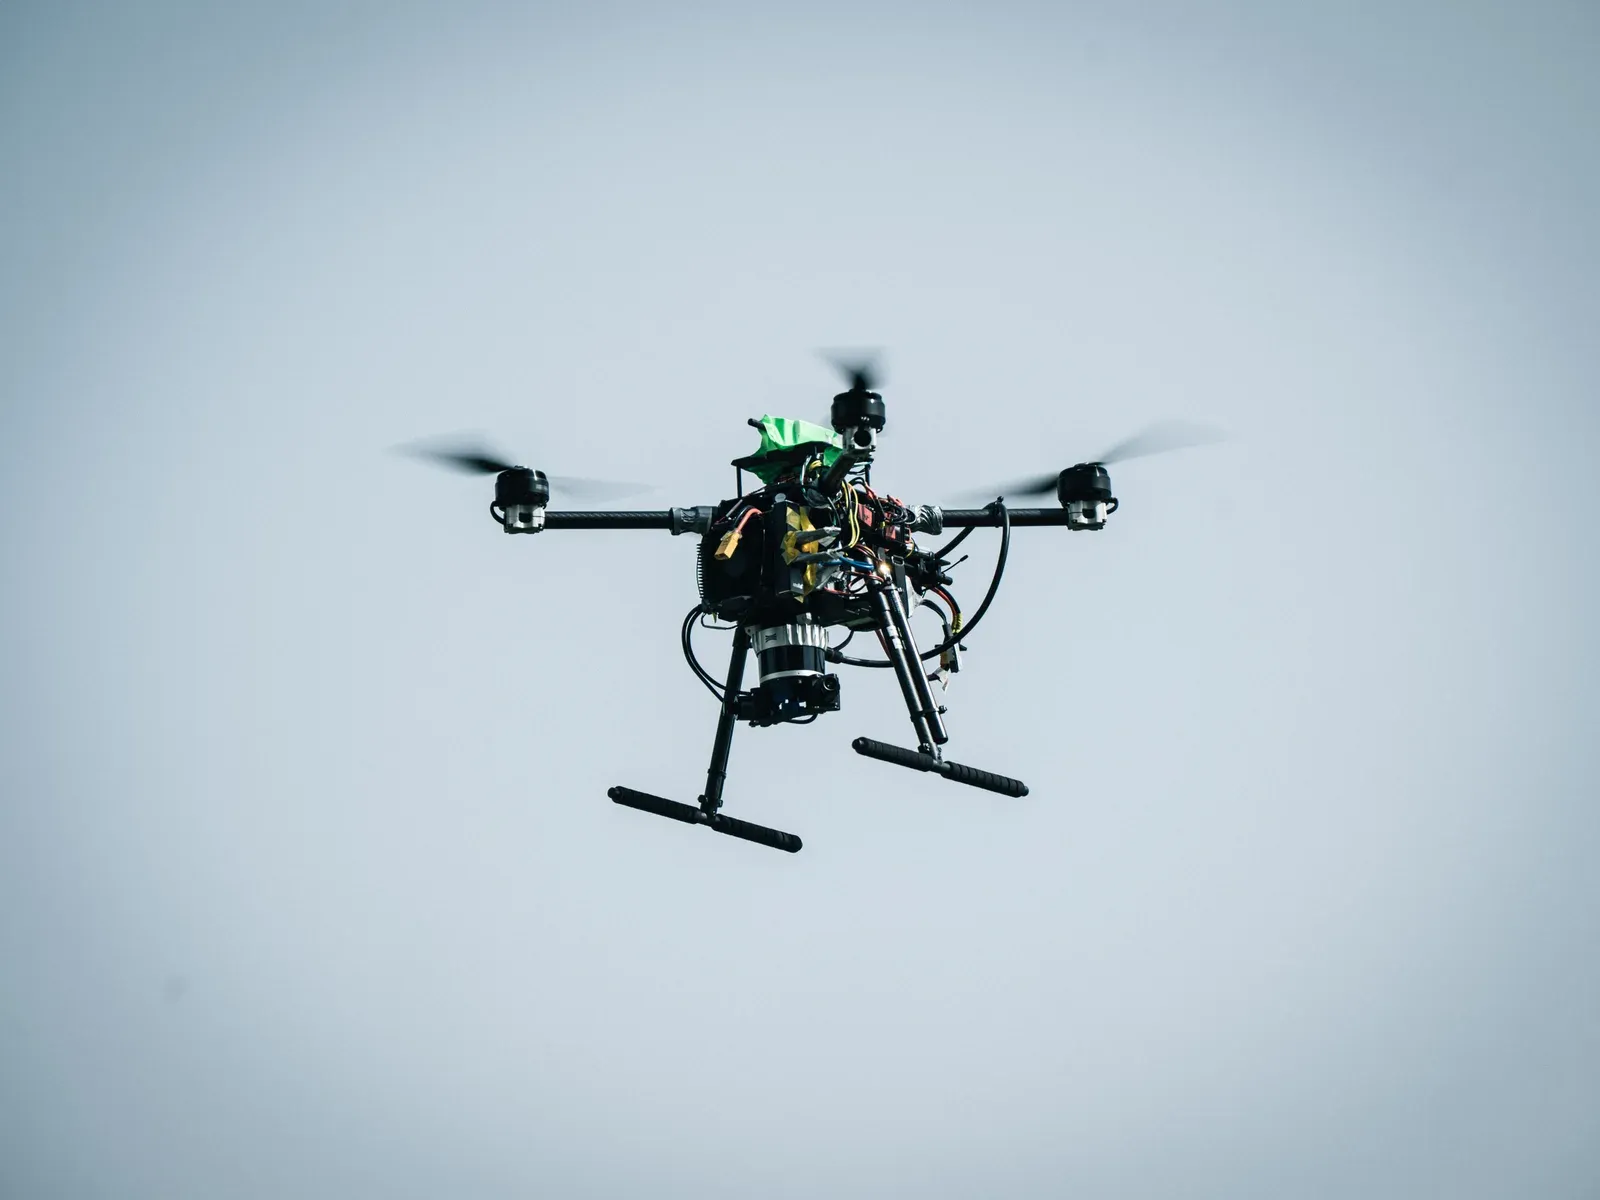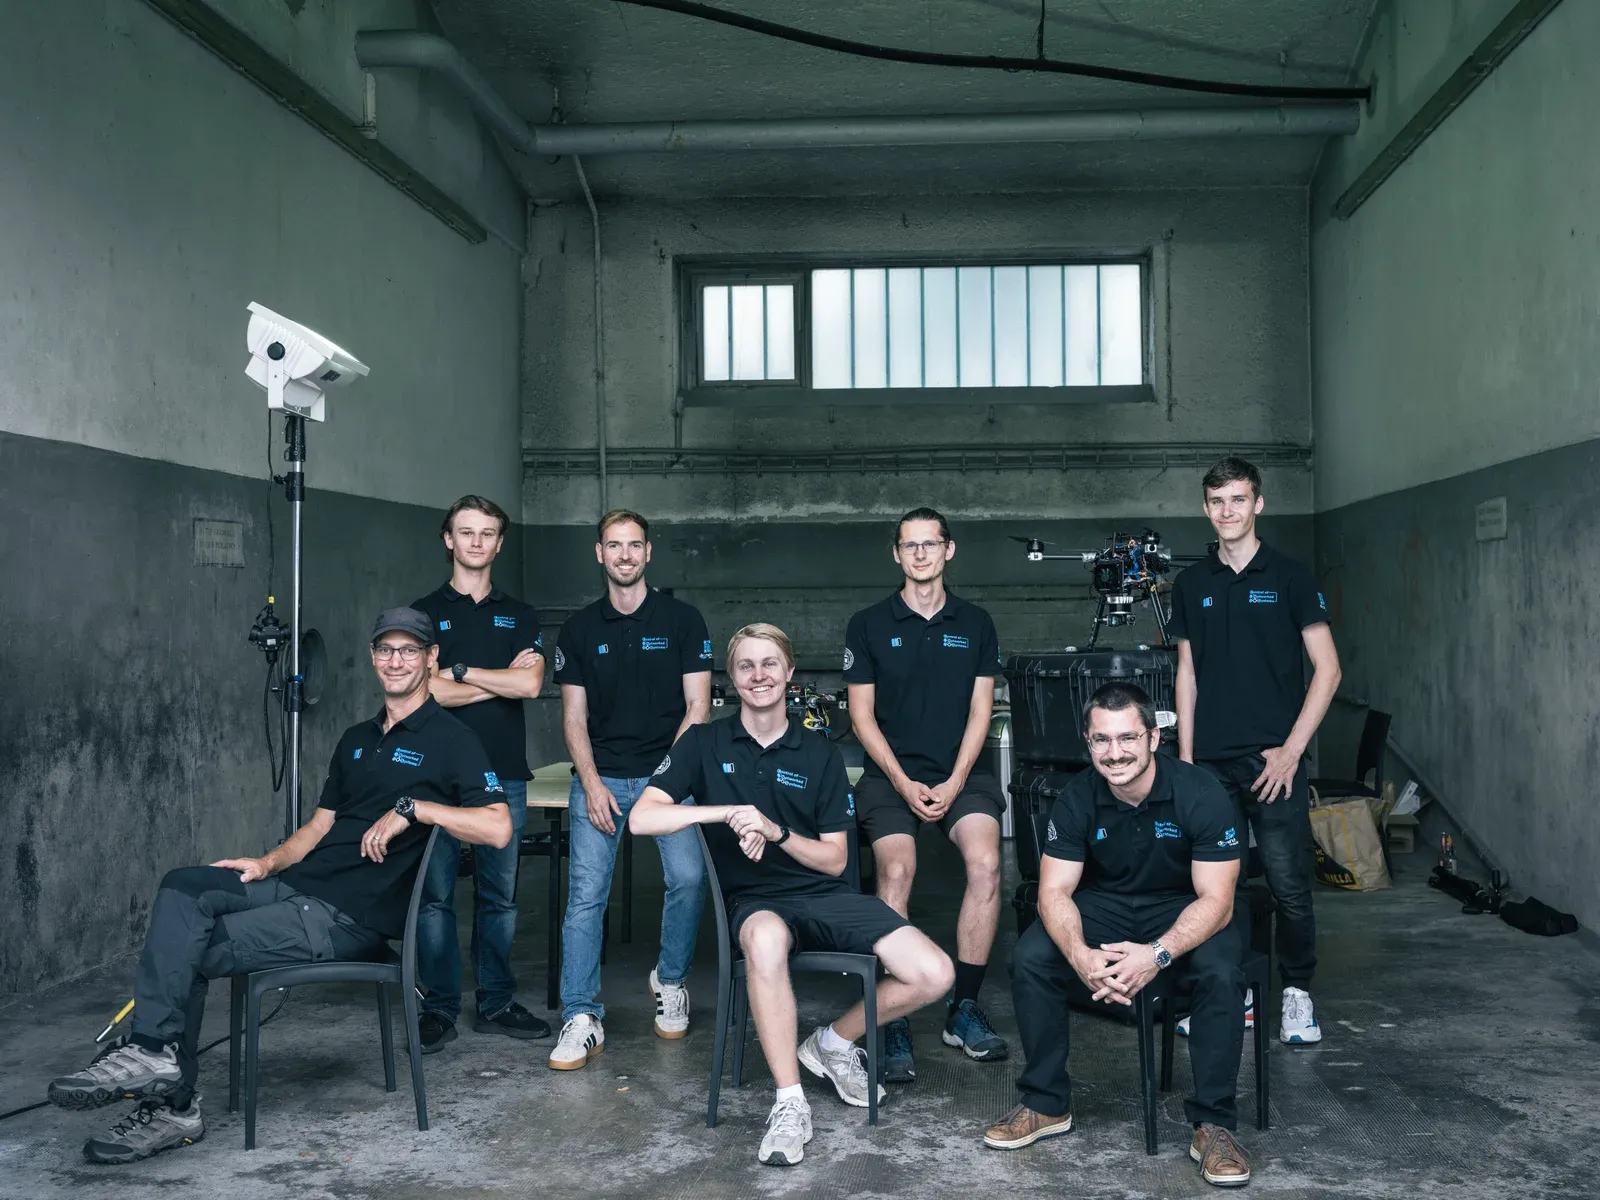
The HERMES team from the Control of Networked Systems (CNS) group at the University of Klagenfurt won Stage 2 of SPRIND’s Fully Autonomous Flight 2.0 Challenge. Fourteen teams were selected for the programme, of which seven advanced to Stage 2. The final took place at Erding Air Base in late August 2026.
Our CEO Luca Di Pierno led the team in developing the core autonomy and overall navigation architecture.
Autonomous mission execution
The UAVs operated autonomously in previously unknown environments without GPS, including missions with two aircraft flying simultaneously. The tasks required navigation, semantic scene understanding, adaptive behaviour, decision-making, reasoning, planning and autonomous mission execution within an integrated software architecture.
The competition tested how these capabilities worked together on the aircraft under real operating conditions. SPRIND’s report on the final describes the missions and the result.
The technical foundation of Vasco
The HERMES autonomy and navigation architecture was developed around modular components and clear interfaces. These design decisions, made two years before the final, supported the integration of different capabilities and development beyond the requirements of a single competition.
The autonomy and navigation technology used by HERMES forms the technical foundation of Vasco Robotics. We build on it to develop modular, hardware-agnostic autonomy software, with UAVs as our current focus. Our work extends the underlying software architecture towards use across aircraft platforms, with components that can be developed, tested and adapted independently.
Team and programme
We thank the CNS students, researchers and supervisors involved in software development, system integration and flight testing. Particular thanks go to Prof. Stephan Weiss for his continued guidance, trust and support throughout the project.
We also thank SPRIND, Germany’s Federal Agency for Breakthrough Innovation, for organising the challenge and supporting the participating teams. Details of the programme and teams are available on the official challenge page.
Photos and video